The International Journal of Robotics Research · 2026
2-minute teaser: the seven tasks, then the ideas behind them.
We build a policy for multi-stage contact-rich manipulation from a single human demonstration. Environmental constraints are the inductive bias: they separate a general policy template, shared by all task instances, from instance-specific details such as poses and geometry, which compliant execution completes at run time. With self-guided augmentation and a few corrections, the policy generalizes to unseen poses and geometries on seven real-world tasks, with over 90% success.
Real-world contact-rich manipulation tasks
Choose a task to watch its experiment video.
Insertion puzzles · Extension 2 · 6:05
How it works
General policy template + instance-specific completion
A policy generalizes when learning captures only what all task instances share, as a general policy template, and leaves what differs to be completed during execution.
Learning
General policy template
Constraint types and contact transitions, shared across task instances
Execution
Instance-specific completion
Poses, angles and geometry, recovered through compliance and sensory feedback
Environmental constraints are the inductive bias
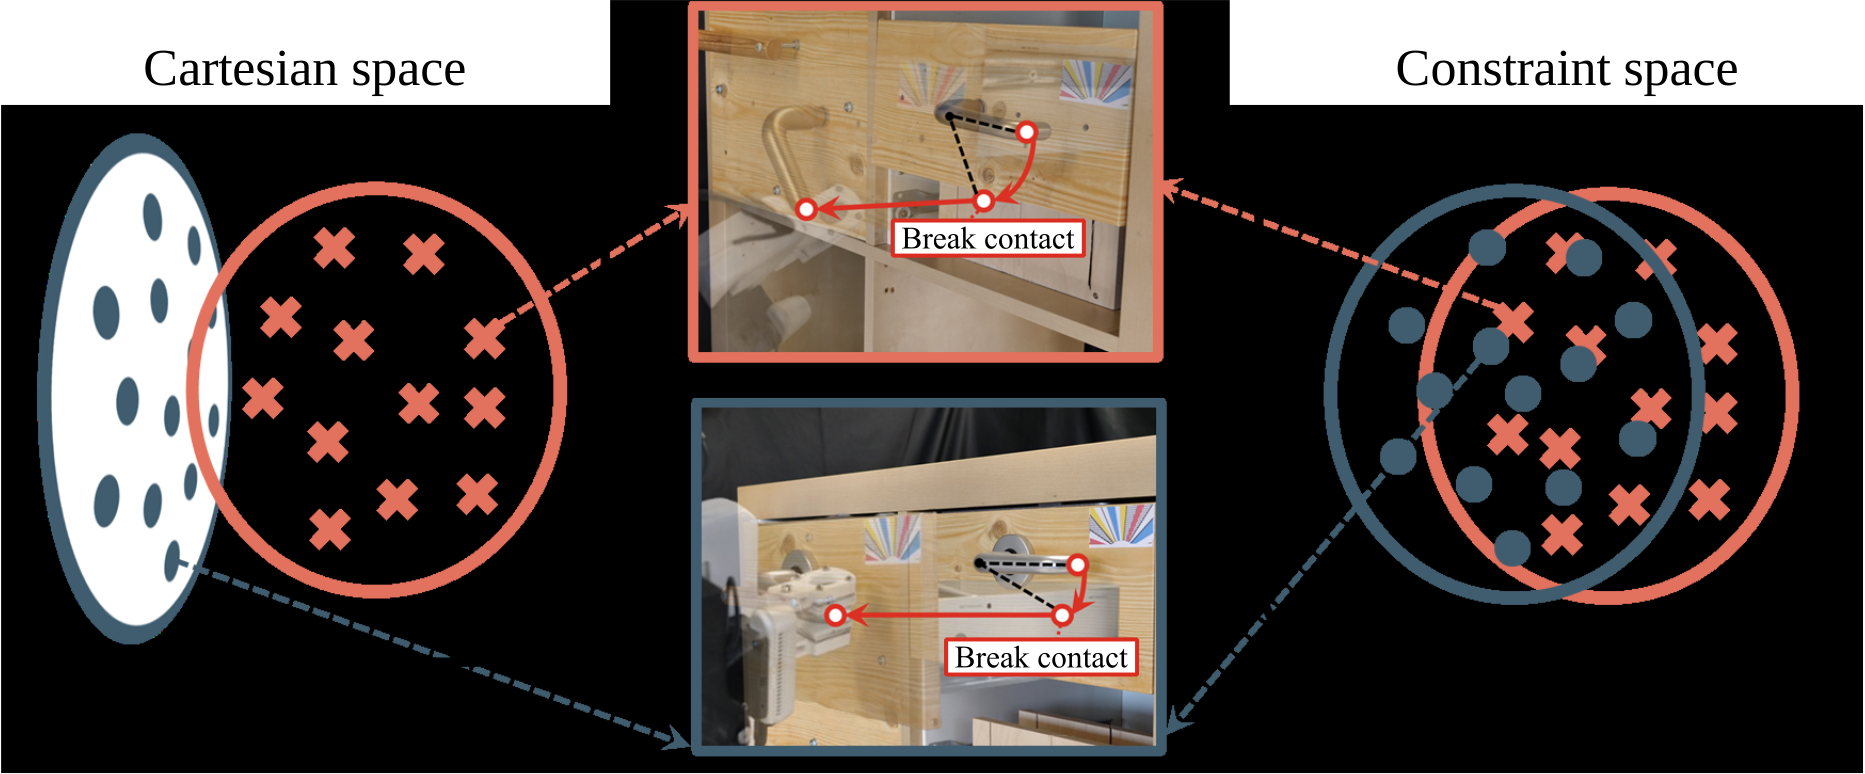
Objects built for the same function share the same constraints: drawers slide, handles turn, keys insert and then rotate. Their geometry differs, but the sequence of constraints and contact transitions is the same, so that is what we learn.
One drawer-opening demonstration, seen two ways. Left: Cartesian trajectories, which differ between the two drawers. Right: constraints and contact transitions, which both drawers share.
The instance-specific details are completed at run time: a compliant controller lets the constraints guide the motion, and the resulting forces and motions reveal the geometry.
Online adaptation during execution · 1:51
Adapting to a 20°, 10 cm axis error · 0:44
Run it in simulation
LfDEC also runs in Isaac Lab / Newton. After setup, one command runs grasping, drawer and door opening, peg insertion and nut turning. Setup instructions ↗
Factory peg insertion
Drawer opening
Cite
@article{li2026lfdec,
  title   = {From a Single Demonstration to a General Policy
             for Contact-Rich Manipulation},
  author  = {Li, Xing and Brock, Oliver},
  journal = {The International Journal of Robotics Research},
  year    = {2026}
}